-
PRODUCTS & SERVICESOptimized cooling solutions for modern data centersProducts & ServicesOptimized cooling solutions for modern data centers
-
CAPABILITIESAdvancing liquid cooling technologiesCapabilitiesAdvancing liquid cooling technologies
-
TechnologiesLiquid Cooling InnovationTechnologiesLiquid Cooling Innovation
-
RESOURCESLatest News & InformationResourcesLatest News & Information
-
ABOUTOur history, leadership and ownershipAboutOur history, leadership and ownership
-
CONTACTFacility locations and global operational footprint

How to Choose Cuav V5+ Flight Controller for Your Drone
Choosing a flight controller is no longer a simple matter of comparing processor speed. Today’s drones carry cameras, navigation sensors, telemetry radios, and safety systems. A weak integration choice can create vibration, noise, or frustrating field failures. This guide examines how to choose a Cuav V5+ Flight Controller for different aircraft sizes, missions, and pilot experience levels.
Industry data shows why careful selection matters. The FAA’s 2024 Aerospace Forecast reported more than 850,000 registered civil drones in the United States, including recreational and commercial aircraft. Meanwhile, Drone Industry Insights continues to document strong growth in commercial drone adoption across inspection, mapping, agriculture, and public safety. More aircraft mean more demanding expectations for reliability, logging, redundancy, and maintenance. Those expectations should shape a controller decision.
The Cuav V5+ Flight Controller is built around the Pixhawk ecosystem and supports advanced autopilot platforms such as PX4 and ArduPilot. Its sensor layout, vibration isolation, power-management options, and communication interfaces deserve close inspection. PX4 documentation emphasizes correct sensor calibration, secure mounting, and consistent power delivery. These details sound ordinary. They are not. A loose screw beside a propeller can ruin an otherwise capable build. Specifications alone cannot guarantee performance. Real results depend on firmware configuration, wiring quality, electromagnetic interference, and testing discipline. I would not choose this controller only because it has more ports. The better question is practical: can it support your mission, payload, frame, and maintenance habits without creating unnecessary complexity?
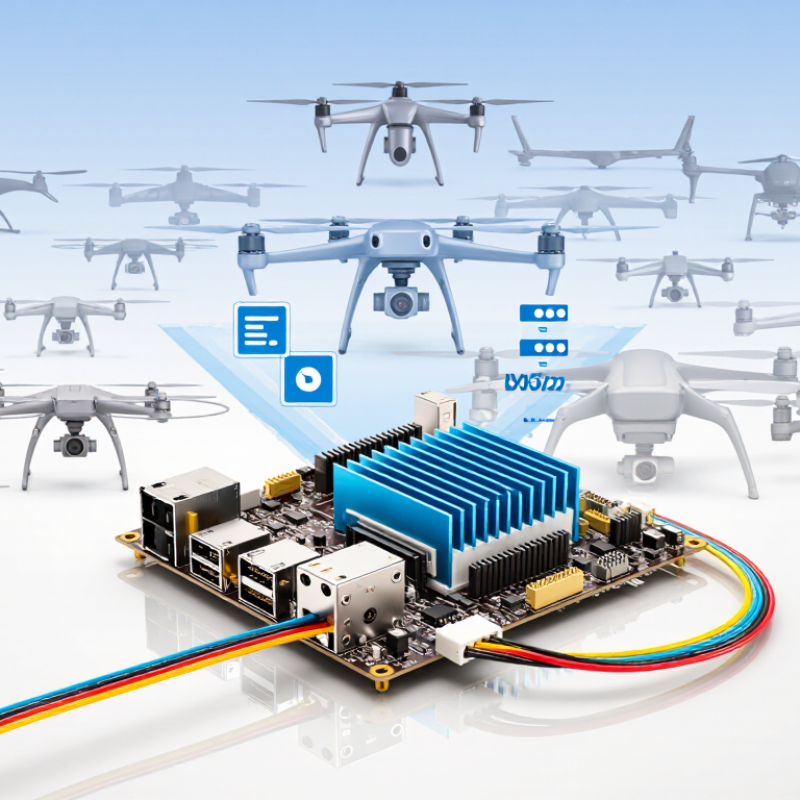
Table of Contents [Hide]
Understanding the Cuav V5+ Flight Controller’s Core Features
When choosing a professional flight controller, study its core hardware before comparing prices. A reliable board should offer dual inertial sensors, stable barometric measurement, and effective vibration management. These features help maintain accurate attitude data during fast turns and uneven motor output. I also check the processor’s capacity, because advanced navigation, camera control, and safety routines can compete for computing resources. More ports matter too. Multiple serial interfaces, CAN connections, PWM outputs, and expansion pads make future upgrades easier.
Power design deserves close attention. Look for separated power inputs, clear voltage limits, and dependable current monitoring. A loose connector can create misleading sensor logs or cause a sudden system restart. During bench testing, I examine solder joints, connector strength, and cable clearance around the frame. Small details matter. The mounting pattern should match the drone’s frame, while the controller should sit away from strong electrical noise. Soft mounting may reduce vibration, but excessive flexibility can make the sensor data worse.
I once focused too much on processor speed and overlooked installation space. That was a poor decision. A controller can have excellent specifications yet remain inconvenient in a compact frame. Before buying, confirm firmware support, calibration procedures, documented wiring, and replacement availability. Test the power monitor with a known load, then review flight logs after short, low-risk flights. Do not trust default settings blindly. Real performance depends on the entire aircraft, not the controller alone.